Reliable positioning is becoming increasingly important across autonomous vehicles, railway inspection, mobile mapping, surveying, industrial equipment, and machine control systems. In many of these applications, a navigation system cannot depend entirely on continuous GNSS reception.
GNSS can provide accurate position, velocity, and timing information when satellite signals are available. However, tunnels, dense urban environments, obstructions, interference, and other challenging conditions can interrupt or degrade satellite reception.
This is where an Inertial Navigation System (INS) can provide an important additional source of navigation data. By combining inertial measurements with GNSS through an integrated navigation solution, platforms can maintain more continuous information about their position, velocity, and attitude.
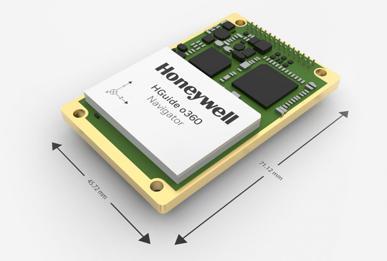
The HGuide o360 is a single-card INS/GNSS navigator designed for applications requiring integrated navigation performance within an ultra-low SWaP (Size, Weight, and Power) package. Its combination of inertial sensing, GNSS integration, navigation algorithms, and application-specific operating modes makes it suitable for a range of land-based and industrial platforms.
Why GNSS and INS Work Better Together
GNSS and INS solve navigation problems from different perspectives.
GNSS determines position and velocity using signals received from satellites. INS, on the other hand, measures the platform's acceleration and angular motion using inertial sensors.
When GNSS reception is stable, GNSS measurements can provide an external reference for the inertial navigation solution. When satellite signals are temporarily unavailable, the INS can continue estimating the platform's motion.
This complementary architecture provides several practical advantages:
-
GNSS supplies an external positioning reference.
-
INS provides continuous high-rate motion measurements.
-
Navigation algorithms combine measurements from different sources.
-
Temporary GNSS interruptions do not necessarily result in an immediate loss of navigation output.
-
GNSS measurements can help constrain accumulated inertial errors when reception is restored.
The goal is therefore not to replace GNSS with INS. Instead, INS/GNSS integration creates a navigation solution that is better suited to environments where satellite availability can change.
What Happens When a Vehicle Enters a GNSS-Denied Area?
Consider a vehicle traveling through an open environment before entering a tunnel.
Before entering the tunnel, the navigation system can use GNSS measurements together with inertial data. Once the vehicle enters the tunnel and satellite reception becomes unreliable, the INS continues measuring acceleration and angular movement.
The navigation algorithm can use those measurements to continue estimating the vehicle's movement.
Of course, inertial navigation is subject to accumulated error over time. An INS should therefore not be viewed as an unlimited substitute for GNSS. Its practical role is to bridge temporary signal interruptions and maintain navigation continuity until reliable external positioning information becomes available again.
This capability is valuable for applications such as:
-
Autonomous and industrial vehicles
-
Railway inspection systems
-
Mobile mapping platforms
-
Surveying equipment
-
Machine-control systems
-
Land-based robotic platforms
-
Navigation in partially obstructed environments
Sensor Quality and Navigation Algorithms Both Matter
The performance of an INS/GNSS system depends on more than the nominal specifications of its inertial sensors.
Small errors in acceleration or angular-rate measurements can accumulate during inertial navigation. Sensor calibration, compensation, and navigation algorithms therefore play an important role in maintaining the quality of the navigation solution.
The HGuide o360 incorporates Honeywell-developed inertial sensor technology and navigation algorithms. These technologies help process inertial measurements and integrate them with available GNSS information.
For engineers evaluating navigation equipment, this is an important consideration. A complete INS/GNSS navigator should be evaluated as an integrated system rather than by comparing one sensor specification in isolation.
Factors such as calibration, compensation, algorithm design, external inputs, and operating modes can all affect real-world performance.
Land Constraints for Vehicle and Railway Applications
Different platforms do not move in the same way.
An aerial platform may move freely in three dimensions, while a road vehicle is generally constrained by a roadway. A railway vehicle has an even stronger constraint because its movement follows a defined track.
The HGuide o360 supports vehicle and railroad operating modes with land constraints. These constraints allow the navigation solution to account for known characteristics of land-based motion.
For vehicle applications, incorporating movement constraints can help the navigation system better represent how the platform actually operates. Railway applications can benefit from the highly constrained nature of track-based movement.
This demonstrates why software configuration is an important part of INS/GNSS selection. The best navigation system is not necessarily the one with the highest standalone sensor specification, but the one whose architecture and operating modes match the platform.
Odometer and DMI Inputs for Land Navigation
External vehicle measurements can provide another useful source of navigation information.
The HGuide o360 supports a standard odometer or DMI input. Depending on the application, this information can supplement GNSS and inertial measurements.
For example, wheel-based speed or distance information can provide additional information about vehicle movement when satellite reception is temporarily degraded.
However, odometer integration requires proper system configuration and calibration. Wheel slip, sensor scaling, mechanical installation, and vehicle dynamics can all influence the quality of the measurement.
For this reason, engineers should consider the INS/GNSS navigator as part of a broader vehicle navigation architecture rather than as an isolated device.
Using NTRIP Corrections for Enhanced GNSS Positioning
Not every navigation application requires the same positioning performance.
General vehicle navigation may tolerate relatively broad positioning errors, while surveying, mapping, inspection, and machine-control applications may require more precise GNSS references.
The HGuide o360 supports onboard NTRIP and accepts RTCM3 GNSS corrections. This enables integration with suitable GNSS correction services when enhanced positioning performance is required.
In a typical corrected navigation setup, GNSS provides an improved external reference while the INS supplies continuous motion information.
Actual positioning performance still depends on multiple factors, including:
-
GNSS correction service quality
-
Antenna performance
-
Satellite visibility
-
Multipath conditions
-
Environmental obstructions
-
Installation quality
-
Overall system configuration
Therefore, NTRIP capability should be considered one part of the complete positioning architecture rather than treated as an automatic accuracy guarantee.
RINEX Generation for Surveying and Post-Processing
Some navigation applications require more than real-time positioning.
Surveying, mobile mapping, inspection, research, and field-testing projects may require recorded GNSS data for additional analysis after data collection.
The HGuide o360 supports RINEX generation, giving users an option to work with recorded GNSS information during post-processing workflows.
Post-processing can be useful when engineers need to refine navigation results, compare field measurements, investigate GNSS reception, or evaluate system performance under specific operating conditions.
This capability can also help during system development because recorded field data can be reviewed after a test run rather than relying entirely on real-time observations.
Ultra-Low SWaP for Compact Navigation Platforms
Size, weight, and power consumption can become important constraints when navigation equipment is integrated into compact vehicles, robots, inspection platforms, or industrial systems.
The HGuide o360 uses a single-card architecture designed for an ultra-low SWaP package. This can simplify integration where enclosure space or available power is limited.
However, SWaP should not be evaluated independently.
Engineers should also review:
-
Physical dimensions
-
Mounting orientation
-
Power requirements
-
Communication interfaces
-
GNSS antenna installation
-
Environmental conditions
-
Data output requirements
-
External sensor interfaces
A compact navigation system is most useful when its mechanical, electrical, and software interfaces can be integrated smoothly into the host platform.
Cross-Platform Compatibility and System Development
Navigation equipment is often used across multiple product platforms.
A manufacturer developing road vehicles, railway inspection equipment, mapping platforms, or industrial systems may prefer navigation products that share a common technology ecosystem.
The HGuide o360 offers cross-platform compatibility with the HGuide n380 and n580. This can help engineering teams maintain a more consistent approach to navigation integration across different projects.
A common product family can potentially simplify software development, testing, system integration, operator training, and maintenance when multiple navigation configurations are required.
What Should Engineers Check Before Selecting an INS/GNSS?
Choosing an INS/GNSS navigator should begin with the actual application environment.
Before purchasing, engineers should evaluate:
1. Navigation performance requirements
Determine the required position, velocity, heading, and attitude performance.
2. GNSS availability
Identify where satellite reception may be obstructed or interrupted.
3. Expected outage duration
Estimate how long the platform may operate without reliable GNSS measurements.
4. Platform dynamics
Consider whether the system will be used on a road vehicle, railway platform, mapping system, robot, or another type of platform.
5. External measurements
Determine whether odometer, DMI, or other external inputs are available.
6. Correction requirements
Check whether RTK, NTRIP, or other GNSS correction services are required.
7. SWaP limitations
Confirm available installation space, power supply, and allowable equipment weight.
8. Data and communication interfaces
Make sure the navigator can communicate with the platform's existing control and data-processing systems.
9. Post-processing requirements
Determine whether recorded GNSS data or RINEX output will be required.
10. Integration and technical support
Evaluate calibration, installation, configuration, and technical support requirements before deployment.
Working With an Experienced Navigation Technology Supplier
The performance of an INS/GNSS system depends not only on the hardware itself but also on how it is selected, installed, configured, and integrated into the host platform.
Shanghai Bingyin Electronics Co., Ltd. was established in 2003 and has more than two decades of experience in navigation and sensor-related technologies. The company specializes in high-temperature accelerometers, HGuide inertial navigation systems, high-precision pressure sensors, and advanced magnetic sensors.
Bingyin Electronics is a Honeywell franchised distributor and provides professional support for Honeywell technologies. Its product portfolio serves applications including energy, oil and gas, measurement-while-drilling, mining, industrial navigation, and other demanding environments.
For customers developing compact navigation platforms, the HGuide o360 INS/GNSS provides an integrated approach combining inertial measurements, GNSS positioning, land constraints, odometer/DMI input, NTRIP correction support, and RINEX generation.
Conclusion
Reliable navigation in real-world environments requires more than continuous access to satellite signals. Tunnels, buildings, terrain, interference, and other obstructions can affect GNSS availability, creating challenges for vehicles, mapping systems, railway equipment, and industrial platforms.
INS/GNSS integration addresses this challenge by combining external GNSS positioning with continuous inertial measurements. When GNSS is available, it can help constrain inertial drift. When GNSS becomes temporarily unavailable, inertial measurements can continue supporting the navigation solution.
Features such as calibrated inertial sensors, Honeywell navigation algorithms, land constraints, odometer input, RTCM3 correction support, RINEX generation, and an ultra-low SWaP architecture can further improve the practicality of an integrated navigation system.
For engineers developing compact platforms that require continuous and reliable navigation data, the key is to select an INS/GNSS solution according to the complete application environment—not simply a single accuracy specification
www.bingyinelec.com
Bingyin Electronics